| ### Statement | | ### Statement |
| | | |
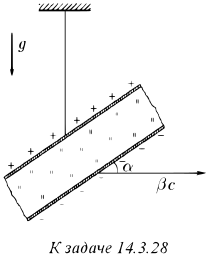
| $14.3.28.$ A charged capacitor suspended on a thread, it would seem, cannot move translationally together with the thread and the suspension, if the angle $\alpha$ is not straight, since the magnetic force of interaction of two jointly moving charges creates a rotational moment. This rotational moment could be detected experimentally if we assume that the capacitor moves with the Earth at a speed of $\beta c$. Is it so? | | $14.3.28.$ A charged capacitor suspended on a thread, it would seem, cannot move translationally together with the thread and the suspension, if the angle $\alpha$ is not straight, since the magnetic force of interaction of two jointly moving charges creates a rotational moment. This rotational moment could be detected experimentally if we assume that the capacitor moves with the Earth at a speed of $\beta c$. Is it so? |
| | | |
|  | |  |
| | | |
| ### Solution | | ### Solution |
| | | |
| Consider the capacitor in a reference frame relative to which it, together with the suspension, moves translationally with velocity | | Consider the capacitor in a reference frame relative to which it, together with the suspension, moves translationally with velocity |
| | | |
| $$ | | $$ |
| \mathbf v=c\boldsymbol{\beta}, | | \mathbf v=c\boldsymbol{\beta}, |
| \qquad | | \qquad |
| \beta=\frac{v}{c}. | | \beta=\frac{v}{c}. |
| $$ | | $$ |
| | | |
| Let $\mathbf E$ denote the electric field produced by one plate at the positions of the charges on the other plate. | | Let $\mathbf E$ denote the electric field produced by one plate at the positions of the charges on the other plate. |
| | | |
| When the charged capacitor is in motion, a magnetic field also appears. Therefore, the charges on each plate are acted upon not only by the electric force, but also by the magnetic part of the Lorentz force. | | When the charged capacitor is in motion, a magnetic field also appears. Therefore, the charges on each plate are acted upon not only by the electric force, but also by the magnetic part of the Lorentz force. |
| | | |
| At first sight, the resultant force is not directed along the normal to the plate, which seems to imply that a torque should arise. We will show that this does not lead to any rotation of the capacitor. | | At first sight, the resultant force is not directed along the normal to the plate, which seems to imply that a torque should arise. We will show that this does not lead to any rotation of the capacitor. |
| | | |
| Let $\theta$ be the angle between the normal to the plate and the direction of motion of the capacitor. The electric field can then be decomposed into components parallel and perpendicular to the velocity: | | Let $\theta$ be the angle between the normal to the plate and the direction of motion of the capacitor. The electric field can then be decomposed into components parallel and perpendicular to the velocity: |
| | | |
| $$ | | $$ |
| E_{\parallel}=E\cos\theta, | | E_{\parallel}=E\cos\theta, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| E_{\perp}=E\sin\theta. | | E_{\perp}=E\sin\theta. |
| $$ | | $$ |
| | | |
| Since there is no magnetic field in the rest frame of the capacitor, in the moving frame the electric and magnetic fields are related by | | Since there is no magnetic field in the rest frame of the capacitor, in the moving frame the electric and magnetic fields are related by |
| | | |
| $$ | | $$ |
| \mathbf B=[\boldsymbol{\beta}\times\mathbf E]. | | \mathbf B=[\boldsymbol{\beta}\times\mathbf E]. |
| $$ | | $$ |
| | | |
| The Lorentz force acting on a charge $Q$ of the plate is | | The Lorentz force acting on a charge $Q$ of the plate is |
| | | |
| $$ | | $$ |
| \mathbf F=Q\left(\mathbf E+[\boldsymbol{\beta}\times\mathbf B]\right). | | \mathbf F=Q\left(\mathbf E+[\boldsymbol{\beta}\times\mathbf B]\right). |
| $$ | | $$ |
| | | |
| Substituting the expression for the magnetic field, we obtain | | Substituting the expression for the magnetic field, we obtain |
| | | |
| $$ | | $$ |
| \mathbf F=Q\left(\mathbf E+[\boldsymbol{\beta}\times[\boldsymbol{\beta}\times\mathbf E]]\right). | | \mathbf F=Q\left(\mathbf E+[\boldsymbol{\beta}\times[\boldsymbol{\beta}\times\mathbf E]]\right). |
| $$ | | $$ |
| | | |
| Using the vector identity | | Using the vector identity |
| | | |
| $$ | | $$ |
| [\mathbf a\times[\mathbf a\times\mathbf b]]=\mathbf a(\mathbf a\cdot\mathbf b)-a^2\mathbf b, | | [\mathbf a\times[\mathbf a\times\mathbf b]]=\mathbf a(\mathbf a\cdot\mathbf b)-a^2\mathbf b, |
| $$ | | $$ |
| | | |
| we see that for the component of the field parallel to $\boldsymbol{\beta}$, the magnetic force vanishes. Therefore, | | we see that for the component of the field parallel to $\boldsymbol{\beta}$, the magnetic force vanishes. Therefore, |
| | | |
| $$ | | $$ |
| \boxed{F_{\parallel}=QE_{\parallel}}. | | \boxed{F_{\parallel}=QE_{\parallel}}. |
| $$ | | $$ |
| | | |
| For the transverse component, | | For the transverse component, |
| | | |
| $$ | | $$ |
| [\boldsymbol{\beta}\times[\boldsymbol{\beta}\times\mathbf E_{\perp}]]=-\beta^2\mathbf E_{\perp}. | | [\boldsymbol{\beta}\times[\boldsymbol{\beta}\times\mathbf E_{\perp}]]=-\beta^2\mathbf E_{\perp}. |
| $$ | | $$ |
| | | |
| Hence, | | Hence, |
| | | |
| $$ | | $$ |
| F_{\perp}=QE_{\perp}(1-\beta^2). | | F_{\perp}=QE_{\perp}(1-\beta^2). |
| $$ | | $$ |
| | | |
| Thus, | | Thus, |
| | | |
| $$ | | $$ |
| \boxed{F_{\perp}=QE_{\perp}(1-\beta^2)}. | | \boxed{F_{\perp}=QE_{\perp}(1-\beta^2)}. |
| $$ | | $$ |
| | | |
| Substituting the components of the electric field, we obtain | | Substituting the components of the electric field, we obtain |
| | | |
| $$ | | $$ |
| F_{\parallel}=QE\cos\theta, | | F_{\parallel}=QE\cos\theta, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| F_{\perp}=QE(1-\beta^2)\sin\theta. | | F_{\perp}=QE(1-\beta^2)\sin\theta. |
| $$ | | $$ |
| | | |
| Therefore, | | Therefore, |
| | | |
| $$ | | $$ |
| \frac{F_{\perp}}{F_{\parallel}}=(1-\beta^2)\tan\theta. | | \frac{F_{\perp}}{F_{\parallel}}=(1-\beta^2)\tan\theta. |
| $$ | | $$ |
| | | |
| Thus, the resultant force is indeed not directed along the normal to the plate. | | Thus, the resultant force is indeed not directed along the normal to the plate. |
| | | |
| However, one cannot conclude from this that the acceleration is directed along the force. In relativistic mechanics, force is defined by | | However, one cannot conclude from this that the acceleration is directed along the force. In relativistic mechanics, force is defined by |
| | | |
| $$ | | $$ |
| \mathbf F=\frac{d\mathbf p}{dt}, | | \mathbf F=\frac{d\mathbf p}{dt}, |
| $$ | | $$ |
| | | |
| where | | where |
| | | |
| $$ | | $$ |
| \mathbf p=\gamma M\mathbf v, | | \mathbf p=\gamma M\mathbf v, |
| \qquad | | \qquad |
| \gamma=\frac{1}{\sqrt{1-\beta^2}}. | | \gamma=\frac{1}{\sqrt{1-\beta^2}}. |
| $$ | | $$ |
| | | |
| For the components of acceleration parallel and perpendicular to the velocity, the following relations hold: | | For the components of acceleration parallel and perpendicular to the velocity, the following relations hold: |
| | | |
| $$ | | $$ |
| F_{\parallel}=\gamma^3Ma_{\parallel}, | | F_{\parallel}=\gamma^3Ma_{\parallel}, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| F_{\perp}=\gamma Ma_{\perp}. | | F_{\perp}=\gamma Ma_{\perp}. |
| $$ | | $$ |
| | | |
| Hence, | | Hence, |
| | | |
| $$ | | $$ |
| a_{\parallel}=\frac{F_{\parallel}}{\gamma^3M}, | | a_{\parallel}=\frac{F_{\parallel}}{\gamma^3M}, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| a_{\perp}=\frac{F_{\perp}}{\gamma M}. | | a_{\perp}=\frac{F_{\perp}}{\gamma M}. |
| $$ | | $$ |
| | | |
| Consider the ratio of the acceleration components: | | Consider the ratio of the acceleration components: |
| | | |
| $$ | | $$ |
| \frac{a_{\perp}}{a_{\parallel}}=\frac{F_{\perp}/(\gamma M)}{F_{\parallel}/(\gamma^3M)}. | | \frac{a_{\perp}}{a_{\parallel}}=\frac{F_{\perp}/(\gamma M)}{F_{\parallel}/(\gamma^3M)}. |
| $$ | | $$ |
| | | |
| Therefore, | | Therefore, |
| | | |
| $$ | | $$ |
| \frac{a_{\perp}}{a_{\parallel}}=\gamma^2\frac{F_{\perp}}{F_{\parallel}}. | | \frac{a_{\perp}}{a_{\parallel}}=\gamma^2\frac{F_{\perp}}{F_{\parallel}}. |
| $$ | | $$ |
| | | |
| Substituting the previously found ratio of the force components, | | Substituting the previously found ratio of the force components, |
| | | |
| $$ | | $$ |
| \frac{a_{\perp}}{a_{\parallel}}=\gamma^2(1-\beta^2)\tan\theta. | | \frac{a_{\perp}}{a_{\parallel}}=\gamma^2(1-\beta^2)\tan\theta. |
| $$ | | $$ |
| | | |
| But | | But |
| | | |
| $$ | | $$ |
| \gamma^2(1-\beta^2)=1. | | \gamma^2(1-\beta^2)=1. |
| $$ | | $$ |
| | | |
| Therefore, | | Therefore, |
| | | |
| $$ | | $$ |
| \boxed{\frac{a_{\perp}}{a_{\parallel}}=\tan\theta}. | | \boxed{\frac{a_{\perp}}{a_{\parallel}}=\tan\theta}. |
| $$ | | $$ |
| | | |
| Hence, the acceleration vector makes the same angle $\theta$ with the direction of motion as the normal to the plate does. | | Hence, the acceleration vector makes the same angle $\theta$ with the direction of motion as the normal to the plate does. |
| | | |
| In other words, | | In other words, |
| | | |
| $$ | | $$ |
| \boxed{\mathbf a\perp\text{ the plate}}. | | \boxed{\mathbf a\perp\text{ the plate}}. |
| $$ | | $$ |
| | | |
| This can also be seen directly. From the expressions for the force components, | | This can also be seen directly. From the expressions for the force components, |
| | | |
| $$ | | $$ |
| a_{\parallel}=\frac{QE\cos\theta}{\gamma^3M}, | | a_{\parallel}=\frac{QE\cos\theta}{\gamma^3M}, |
| $$ | | $$ |
| | | |
| while for the transverse component, | | while for the transverse component, |
| | | |
| $$ | | $$ |
| a_{\perp}=\frac{QE(1-\beta^2)\sin\theta}{\gamma M}. | | a_{\perp}=\frac{QE(1-\beta^2)\sin\theta}{\gamma M}. |
| $$ | | $$ |
| | | |
| Since | | Since |
| | | |
| $$ | | $$ |
| 1-\beta^2=\frac{1}{\gamma^2}, | | 1-\beta^2=\frac{1}{\gamma^2}, |
| $$ | | $$ |
| | | |
| we obtain | | we obtain |
| | | |
| $$ | | $$ |
| a_{\perp}=\frac{QE\sin\theta}{\gamma^3M}. | | a_{\perp}=\frac{QE\sin\theta}{\gamma^3M}. |
| $$ | | $$ |
| | | |
| Thus, | | Thus, |
| | | |
| $$ | | $$ |
| a_{\parallel}=\frac{QE}{\gamma^3M}\cos\theta, | | a_{\parallel}=\frac{QE}{\gamma^3M}\cos\theta, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| a_{\perp}=\frac{QE}{\gamma^3M}\sin\theta. | | a_{\perp}=\frac{QE}{\gamma^3M}\sin\theta. |
| $$ | | $$ |
| | | |
| These two components correspond exactly to the decomposition of a vector directed along the normal to the plate. | | These two components correspond exactly to the decomposition of a vector directed along the normal to the plate. |
| | | |
| For the opposite plate, the acceleration has the same magnitude and the opposite direction. Therefore, the electromagnetic interaction causes only mutual attraction of the plates along their common normal and does not produce any relative rotation. | | For the opposite plate, the acceleration has the same magnitude and the opposite direction. Therefore, the electromagnetic interaction causes only mutual attraction of the plates along their common normal and does not produce any relative rotation. |
| | | |
| If we use the angle $\alpha$ shown in the figure, measured between the plate and the direction of motion, then | | If we use the angle $\alpha$ shown in the figure, measured between the plate and the direction of motion, then |
| | | |
| $$ | | $$ |
| \theta=\frac{\pi}{2}-\alpha, | | \theta=\frac{\pi}{2}-\alpha, |
| $$ | | $$ |
| | | |
| so that | | so that |
| | | |
| $$ | | $$ |
| \cos\theta=\sin\alpha, | | \cos\theta=\sin\alpha, |
| \qquad | | \qquad |
| \sin\theta=\cos\alpha. | | \sin\theta=\cos\alpha. |
| $$ | | $$ |
| | | |
| Then | | Then |
| | | |
| $$ | | $$ |
| a_{\parallel}=\frac{QE}{\gamma^3M}\sin\alpha, | | a_{\parallel}=\frac{QE}{\gamma^3M}\sin\alpha, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| a_{\perp}=\frac{QE}{\gamma^3M}\cos\alpha, | | a_{\perp}=\frac{QE}{\gamma^3M}\cos\alpha, |
| $$ | | $$ |
| | | |
| which again shows that the acceleration is directed perpendicular to the plate. | | which again shows that the acceleration is directed perpendicular to the plate. |
| | | |
| Therefore, although the resultant electromagnetic force in the moving frame is not directed along the normal to the plates, the relativistic relation between force and acceleration ensures that the acceleration itself is normal to the plates. | | Therefore, although the resultant electromagnetic force in the moving frame is not directed along the normal to the plates, the relativistic relation between force and acceleration ensures that the acceleration itself is normal to the plates. |
| | | |
| Hence, no rotation of the capacitor occurs. | | Hence, no rotation of the capacitor occurs. |
| | | |
| This is also consistent with the principle of relativity: uniform translational motion of the capacitor together with the Earth cannot be detected by means of an internal mechanical experiment. | | This is also consistent with the principle of relativity: uniform translational motion of the capacitor together with the Earth cannot be detected by means of an internal mechanical experiment. |
| | | |
| #### Answer | | #### Answer |
| | | |
| The resultant electromagnetic force in the moving frame is indeed deflected from the normal to the plate. However, in relativistic mechanics, force and acceleration need not be parallel. | | The resultant electromagnetic force in the moving frame is indeed deflected from the normal to the plate. However, in relativistic mechanics, force and acceleration need not be parallel. |
| | | |
| From the relations | | From the relations |
| | | |
| $$ | | $$ |
| F_{\parallel}=\gamma^3Ma_{\parallel}, | | F_{\parallel}=\gamma^3Ma_{\parallel}, |
| $$ | | $$ |
| | | |
| $$ | | $$ |
| F_{\perp}=\gamma Ma_{\perp}, | | F_{\perp}=\gamma Ma_{\perp}, |
| $$ | | $$ |
| | | |
| it follows that the acceleration components have precisely the ratio required for the acceleration vector to be directed along the normal to the plate. | | it follows that the acceleration components have precisely the ratio required for the acceleration vector to be directed along the normal to the plate. |
| | | |
| Therefore, | | Therefore, |
| | | |
| $$ | | $$ |
