Edit to “Statement”
en/2.1.49.md
+1 −1
| @@ -1,6 +1,6 @@ | |||
| ### Statement | |||
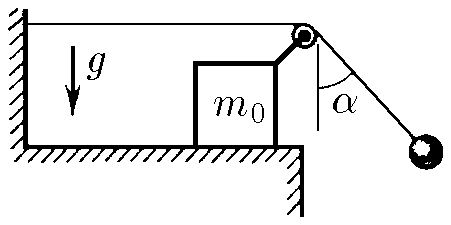
| − | $2.1.49$ A load is suspended from the free end of the thread attached to the wall and thrown over the roller. The roller is fixed on a bar of mass $m_0$, which can slide along a horizontal plane without friction. At the initial moment, the thread with the load is deflected from the vertical by an angle \alpha and then released. Determine the acceleration of the bar if the angle formed by the thread with the vertical does not change during the movement of the system. What is the weight of the cargo? | ||
| + | $2.1.49$ A load is suspended from the free end of the thread attached to the wall and thrown over the roller. The roller is fixed on a bar of mass $m_0$, which can slide along a horizontal plane without friction. At the initial moment, the thread with the load is deflected from the vertical by an angle $\alpha$ and then released. Determine the acceleration of the bar if the angle formed by the thread with the vertical does not change during the movement of the system. What is the weight of the cargo? | ||
|  | |||
| ### Solution | |||
| 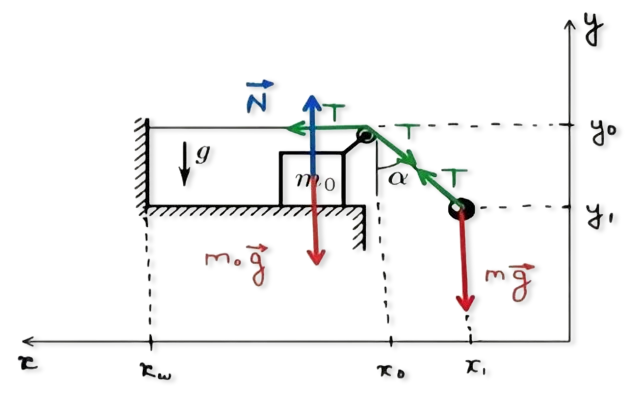 | |||
| Newton's second law of motion: | |||
| $$ | |||
| OX: \;T - T \sin\alpha = m_0 a_{0x} | |||
| $$ | |||
| $$ | |||
| T \sin\alpha = m_{a1x} | |||
| $$ | |||
| $$ | |||
| OY: \;N - mg - T \cos\alpha = m_0 a_{0y} = 0 | |||
| $$ | |||
| $$ | |||
| T \cos\alpha - mg = m_{a1y} | |||
| $$ | |||
| $$ | |||
| \tan\alpha = \frac{x_0 - x_1}{y_0 - y_1} | |||
| $$ | |||
| Since $\alpha = \text{const}$ | |||
| $$ | |||
| \frac{d}{dt} \left( \tan\alpha\right) = \frac{\left( \frac{dx_0}{dt} - \frac{dx_1}{dt} \right)(y_0 - y_1) - \left( \frac{dy_0}{dt} - \frac{dy_1}{dt} \right)(x_0 - x_1)}{(y_0 - y_1)^2} = 0 | |||
| $$ | |||
| $$ | |||
| \frac{d}{dt} \left( \left( \frac{dx_0}{dt} - \frac{dx_1}{dt} \right)(y_0 - y_1) \right) = \frac{d}{dt} \left( \left( \frac{dy_0}{dt} - \frac{dy_1}{dt} \right)(x_0 - x_1) \right) | |||
| $$ | |||
| $$ | |||
| \left(\frac{d^{2}x_{0}}{dt^{2}}-\frac{d^{2}x_{1}}{dt^{2}}\right)(y_{0}-y_{1})+\left(\frac{dx_{0}}{dt}-\frac{dx_{1}}{dt}\right)\left(\frac{dy_{0}}{dt}-\frac{dy_{1}}{dt}\right)= | |||
| $$ | |||
| $$ | |||
| \left(\frac{d^{2}y_{0}}{dt^{2}}-\frac{d^{2}y_{1}}{dt^{2}}\right)(x_{0}-x_{1})+\left(\frac{dy_{0}}{dt}-\frac{dy_{1}}{dt}\right)\cdot\left(\frac{dx_{0}}{dt}-\frac{dx_{1}}{dt}\right) | |||
| $$ | |||
| $$ | |||
| (a_{0x} - a_{1x})(y_0 - y_1) = (a_{0y} - a_{1y})(x_0 - x_1) | |||
| $$ | |||
| $$ | |||
| \tan\alpha (a_{0y} - a_{1y}) = a_{0x} - a_{1x} | |||
| $$ | |||
| From (1) | |||
| $$ | |||
| a_{0y} = 0 | |||
| $$ | |||
| $$ | |||
| -\tan\alpha\, a_{1y} = a_{0x} - a_{1x} | |||
| $$ | |||
| Length of the rope: | |||
| $$ | |||
| L = x_w - x_0 + \frac{y_0 - y_1}{\cos\alpha} | |||
| $$ | |||
| Since the rope is inextensible | |||
| $$ | |||
| \frac{d^2 L}{dt^2} = -\frac{d^2 x_0}{dt^2} + \frac{1}{\cos\alpha} \left( \frac{d^2 y_0}{dt^2} - \frac{d^2 y_1}{dt^2} \right) = 0 | |||
| $$ | |||
| $$ | |||
| \left( \frac{d^2 x_0}{dt^2} = a_{0x}, \frac{d^2 y_0}{dt^2} = a_{0y}, \frac{d^2 y_1}{dt^2} = a_{1y} \right) | |||
| $$ | |||
| $$ | |||
| a_{0x} \cdot \cos\alpha = a_{0y} - a_{1y} | |||
| $$ | |||
| From $(1)$: $a_{0y} = 0$ | |||
| $$ | |||
| a_{0x} \cos\alpha = -a_{1y} | |||
| $$ | |||
| By dividing the equations from (1): | |||
| $$ | |||
| \frac{T \sin\alpha}{T \cos\alpha} = \frac{m a_{1x}}{m (g + a_{1y})} \to \tan\alpha (g + a_{1y}) = a_{1x} | |||
| $$ | |||
| $$ | |||
| \tan\alpha a_{1y} = a_{1x} - g \tan\alpha | |||
| $$ | |||
| and using (4) | |||
| $$ | |||
| \boxed{a_{0x} = g \tan\alpha} | |||
| $$ | |||
| By dividing the equations from (1): | |||
| $$ | |||
| \frac{T(1 - \sin\alpha )}{T \cos\alpha} = \frac{M}{m} \cdot \frac{a_{0x}}{g + a_{1y}} | |||
| $$ | |||
| Note that: | |||
| $$ | |||
| a_{1y} = -g \sin\alpha | |||
| $$ | |||
| $$ | |||
| \frac{1 - \sin\alpha}{\cos\alpha} \frac{M}{m} = \frac{g \tan\alpha}{g - g \sin\alpha} \to m = \frac{M \sin\alpha}{(1 - \sin\alpha )^2} | |||
| $$ | |||
| $$ | |||
| \boxed{m = \frac{M \sin\alpha}{(1 - \sin\alpha )^2}} | |||
| $$ | |||
| unchanged lines 123 | |||
| @@ -1,6 +1,6 @@ | |||
| ### Statement | ### Statement | ||
| $2.1.49$ A load is suspended from the free end of the thread attached to the wall and thrown over the roller. The roller is fixed on a bar of mass $m_0$, which can slide along a horizontal plane without friction. At the initial moment, the thread with the load is deflected from the vertical by an angle \alpha and then released. Determine the acceleration of the bar if the angle formed by the thread with the vertical does not change during the movement of the system. What is the weight of the cargo? | $2.1.49$ A load is suspended from the free end of the thread attached to the wall and thrown over the roller. The roller is fixed on a bar of mass $m_0$, which can slide along a horizontal plane without friction. At the initial moment, the thread with the load is deflected from the vertical by an angle $\alpha$ and then released. Determine the acceleration of the bar if the angle formed by the thread with the vertical does not change during the movement of the system. What is the weight of the cargo? | ||
|  |  | ||
| ### Solution | ### Solution | ||
|  |  | ||
| Newton's second law of motion: | Newton's second law of motion: | ||
| $$ | $$ | ||
| OX: \;T - T \sin\alpha = m_0 a_{0x} | OX: \;T - T \sin\alpha = m_0 a_{0x} | ||
| $$ | $$ | ||
| $$ | $$ | ||
| T \sin\alpha = m_{a1x} | T \sin\alpha = m_{a1x} | ||
| $$ | $$ | ||
| $$ | $$ | ||
| OY: \;N - mg - T \cos\alpha = m_0 a_{0y} = 0 | OY: \;N - mg - T \cos\alpha = m_0 a_{0y} = 0 | ||
| $$ | $$ | ||
| $$ | $$ | ||
| T \cos\alpha - mg = m_{a1y} | T \cos\alpha - mg = m_{a1y} | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \tan\alpha = \frac{x_0 - x_1}{y_0 - y_1} | \tan\alpha = \frac{x_0 - x_1}{y_0 - y_1} | ||
| $$ | $$ | ||
| Since $\alpha = \text{const}$ | Since $\alpha = \text{const}$ | ||
| $$ | $$ | ||
| \frac{d}{dt} \left( \tan\alpha\right) = \frac{\left( \frac{dx_0}{dt} - \frac{dx_1}{dt} \right)(y_0 - y_1) - \left( \frac{dy_0}{dt} - \frac{dy_1}{dt} \right)(x_0 - x_1)}{(y_0 - y_1)^2} = 0 | \frac{d}{dt} \left( \tan\alpha\right) = \frac{\left( \frac{dx_0}{dt} - \frac{dx_1}{dt} \right)(y_0 - y_1) - \left( \frac{dy_0}{dt} - \frac{dy_1}{dt} \right)(x_0 - x_1)}{(y_0 - y_1)^2} = 0 | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \frac{d}{dt} \left( \left( \frac{dx_0}{dt} - \frac{dx_1}{dt} \right)(y_0 - y_1) \right) = \frac{d}{dt} \left( \left( \frac{dy_0}{dt} - \frac{dy_1}{dt} \right)(x_0 - x_1) \right) | \frac{d}{dt} \left( \left( \frac{dx_0}{dt} - \frac{dx_1}{dt} \right)(y_0 - y_1) \right) = \frac{d}{dt} \left( \left( \frac{dy_0}{dt} - \frac{dy_1}{dt} \right)(x_0 - x_1) \right) | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \left(\frac{d^{2}x_{0}}{dt^{2}}-\frac{d^{2}x_{1}}{dt^{2}}\right)(y_{0}-y_{1})+\left(\frac{dx_{0}}{dt}-\frac{dx_{1}}{dt}\right)\left(\frac{dy_{0}}{dt}-\frac{dy_{1}}{dt}\right)= | \left(\frac{d^{2}x_{0}}{dt^{2}}-\frac{d^{2}x_{1}}{dt^{2}}\right)(y_{0}-y_{1})+\left(\frac{dx_{0}}{dt}-\frac{dx_{1}}{dt}\right)\left(\frac{dy_{0}}{dt}-\frac{dy_{1}}{dt}\right)= | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \left(\frac{d^{2}y_{0}}{dt^{2}}-\frac{d^{2}y_{1}}{dt^{2}}\right)(x_{0}-x_{1})+\left(\frac{dy_{0}}{dt}-\frac{dy_{1}}{dt}\right)\cdot\left(\frac{dx_{0}}{dt}-\frac{dx_{1}}{dt}\right) | \left(\frac{d^{2}y_{0}}{dt^{2}}-\frac{d^{2}y_{1}}{dt^{2}}\right)(x_{0}-x_{1})+\left(\frac{dy_{0}}{dt}-\frac{dy_{1}}{dt}\right)\cdot\left(\frac{dx_{0}}{dt}-\frac{dx_{1}}{dt}\right) | ||
| $$ | $$ | ||
| $$ | $$ | ||
| (a_{0x} - a_{1x})(y_0 - y_1) = (a_{0y} - a_{1y})(x_0 - x_1) | (a_{0x} - a_{1x})(y_0 - y_1) = (a_{0y} - a_{1y})(x_0 - x_1) | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \tan\alpha (a_{0y} - a_{1y}) = a_{0x} - a_{1x} | \tan\alpha (a_{0y} - a_{1y}) = a_{0x} - a_{1x} | ||
| $$ | $$ | ||
| From (1) | From (1) | ||
| $$ | $$ | ||
| a_{0y} = 0 | a_{0y} = 0 | ||
| $$ | $$ | ||
| $$ | $$ | ||
| -\tan\alpha\, a_{1y} = a_{0x} - a_{1x} | -\tan\alpha\, a_{1y} = a_{0x} - a_{1x} | ||
| $$ | $$ | ||
| Length of the rope: | Length of the rope: | ||
| $$ | $$ | ||
| L = x_w - x_0 + \frac{y_0 - y_1}{\cos\alpha} | L = x_w - x_0 + \frac{y_0 - y_1}{\cos\alpha} | ||
| $$ | $$ | ||
| Since the rope is inextensible | Since the rope is inextensible | ||
| $$ | $$ | ||
| \frac{d^2 L}{dt^2} = -\frac{d^2 x_0}{dt^2} + \frac{1}{\cos\alpha} \left( \frac{d^2 y_0}{dt^2} - \frac{d^2 y_1}{dt^2} \right) = 0 | \frac{d^2 L}{dt^2} = -\frac{d^2 x_0}{dt^2} + \frac{1}{\cos\alpha} \left( \frac{d^2 y_0}{dt^2} - \frac{d^2 y_1}{dt^2} \right) = 0 | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \left( \frac{d^2 x_0}{dt^2} = a_{0x}, \frac{d^2 y_0}{dt^2} = a_{0y}, \frac{d^2 y_1}{dt^2} = a_{1y} \right) | \left( \frac{d^2 x_0}{dt^2} = a_{0x}, \frac{d^2 y_0}{dt^2} = a_{0y}, \frac{d^2 y_1}{dt^2} = a_{1y} \right) | ||
| $$ | $$ | ||
| $$ | $$ | ||
| a_{0x} \cdot \cos\alpha = a_{0y} - a_{1y} | a_{0x} \cdot \cos\alpha = a_{0y} - a_{1y} | ||
| $$ | $$ | ||
| From $(1)$: $a_{0y} = 0$ | From $(1)$: $a_{0y} = 0$ | ||
| $$ | $$ | ||
| a_{0x} \cos\alpha = -a_{1y} | a_{0x} \cos\alpha = -a_{1y} | ||
| $$ | $$ | ||
| By dividing the equations from (1): | By dividing the equations from (1): | ||
| $$ | $$ | ||
| \frac{T \sin\alpha}{T \cos\alpha} = \frac{m a_{1x}}{m (g + a_{1y})} \to \tan\alpha (g + a_{1y}) = a_{1x} | \frac{T \sin\alpha}{T \cos\alpha} = \frac{m a_{1x}}{m (g + a_{1y})} \to \tan\alpha (g + a_{1y}) = a_{1x} | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \tan\alpha a_{1y} = a_{1x} - g \tan\alpha | \tan\alpha a_{1y} = a_{1x} - g \tan\alpha | ||
| $$ | $$ | ||
| and using (4) | and using (4) | ||
| $$ | $$ | ||
| \boxed{a_{0x} = g \tan\alpha} | \boxed{a_{0x} = g \tan\alpha} | ||
| $$ | $$ | ||
| By dividing the equations from (1): | By dividing the equations from (1): | ||
| $$ | $$ | ||
| \frac{T(1 - \sin\alpha )}{T \cos\alpha} = \frac{M}{m} \cdot \frac{a_{0x}}{g + a_{1y}} | \frac{T(1 - \sin\alpha )}{T \cos\alpha} = \frac{M}{m} \cdot \frac{a_{0x}}{g + a_{1y}} | ||
| $$ | $$ | ||
| Note that: | Note that: | ||
| $$ | $$ | ||
| a_{1y} = -g \sin\alpha | a_{1y} = -g \sin\alpha | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \frac{1 - \sin\alpha}{\cos\alpha} \frac{M}{m} = \frac{g \tan\alpha}{g - g \sin\alpha} \to m = \frac{M \sin\alpha}{(1 - \sin\alpha )^2} | \frac{1 - \sin\alpha}{\cos\alpha} \frac{M}{m} = \frac{g \tan\alpha}{g - g \sin\alpha} \to m = \frac{M \sin\alpha}{(1 - \sin\alpha )^2} | ||
| $$ | $$ | ||
| $$ | $$ | ||
| \boxed{m = \frac{M \sin\alpha}{(1 - \sin\alpha )^2}} | \boxed{m = \frac{M \sin\alpha}{(1 - \sin\alpha )^2}} | ||
| $$ | $$ | ||
| unchanged lines 123 | |||