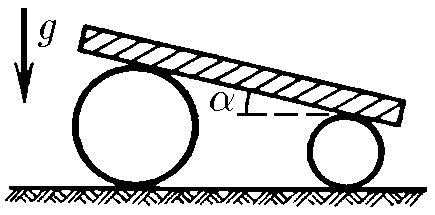
**2.1.51.** A heavy plate is placed on two rollers of different radii. The plate forms an angle $\alpha$ with the horizontal. Find the acceleration of this plate. There is no slipping. The masses of the rollers are negligible.
+
$2.1.51.$ A heavy plate is placed on two rollers of different radii. The plate forms an angle $\alpha$ with the horizontal. Find the acceleration of this plate. There is no slipping. The masses of the rollers are negligible.
−
---
### Solution:
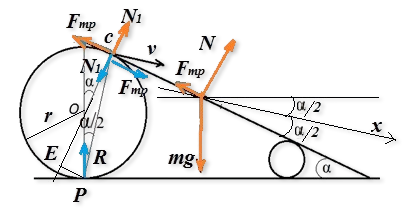
The motion of the plate is complex: it consists of horizontal motion (due to the rolling of the rollers) and motion at an angle to the horizontal, but overall it is translational. Let us mark the forces.
−
*Blue vectors represent forces acting on the roller ($N_1$ — the force from the plate on the roller, equal and opposite to the force from the roller on the plate; $F_{fr}$ — the friction force acting on the roller, which causes its rotation; and the reaction force $R$ at point $P$).
−
*Similar forces act on the smaller-radius roller.
−
*Red vectors represent forces acting on the plate ($N$ — the total normal force, $mg$ — the gravitational force, and $F_{fr}$ — the friction force from the rollers on the plate).
+
Blue vectors represent forces acting on the roller ($N_1$ — the force from the plate on the roller, equal and opposite to the force from the roller on the plate; $F_{fr}$ — the friction force acting on the roller, which causes its rotation; and the reaction force $R$ at point $P$).
+
Similar forces act on the smaller-radius roller.
+
Red vectors represent forces acting on the plate ($N$ — the total normal force, $mg$ — the gravitational force, and $F_{fr}$ — the friction force from the rollers on the plate).
We choose the $Ox$ axis along the velocity of the plate. The velocity itself is the instantaneous velocity of the point of contact between the plate and the roller, while point $P$ is the instantaneous center of velocity. The velocity $v$ is perpendicular to $PC$ (the instantaneous radius of rotation).
Writing the equation of motion for the plate in projections on the $Ox$ axis:
$$
ma = mg \sin\frac{\alpha}{2} + N \sin\frac{\alpha}{2} - F_{fr}\cos\frac{\alpha}{2}\tag{1}
$$
This equation contains three unknowns. We need more equations.
Now let’s write the rotational equation of motion for the roller:
$$
I \varepsilon = \Sigma M
$$
That is, the product of the moment of inertia and the angular acceleration equals the sum of the torques acting on the roller.
@@ -42,19 +35,18 @@Solution:
The lever arms of the forces acting on the roller (relative to $PC$) are:
−
*For force $F_{fr}$:
+
For force $F_{fr}$:
$$
2r \cos^2 \frac{\alpha}{2}
$$
−
*For force $N$:
+
For force $N$:
$$
2r \cos\frac{\alpha}{2}\cdot\sin\frac{\alpha}{2}
−
$$
+
$$
+
+
For force $R$: zero.
−
* For force $R$:
−
zero.
−
Thus, the rotational equation for the roller is (since the roller mass is negligible, $I=0$):
$$
0 = - F_{fr}\cdot 2r \cos^2 \frac{\alpha}{2} + N r \sin\alpha\tag{2}
$$
From here:
$$
F_{fr} = N \tan\frac{\alpha}{2}
$$
Substituting this into equation (1), we get:
$$
ma = mg \sin\frac{\alpha}{2}
$$
Thus, the required acceleration is:
$$
@@ -79,20 +71,13 @@Solution:
\boxed{a = g \sin\frac{\alpha}{2}}
$$
−
---
#### Answer:
$$
a = g \sin\frac{\alpha}{2}
$$
−
---
−
### Alternative Solution:

−
−
#### Answer
−
−
[Insert a concise answer or boxed result]
@@ -1,26 +1,19 @@
### Statement
$2.1.51.$ [Insert the problem statement]
### Solution
### Problem Statement:
### Problem Statement:
**2.1.51.** A heavy plate is placed on two rollers of different radii. The plate forms an angle $\alpha$ with the horizontal. Find the acceleration of this plate. There is no slipping. The masses of the rollers are negligible.
$2.1.51.$ A heavy plate is placed on two rollers of different radii. The plate forms an angle $\alpha$ with the horizontal. Find the acceleration of this plate. There is no slipping. The masses of the rollers are negligible.


---
### Solution:
### Solution:


The motion of the plate is complex: it consists of horizontal motion (due to the rolling of the rollers) and motion at an angle to the horizontal, but overall it is translational. Let us mark the forces.
The motion of the plate is complex: it consists of horizontal motion (due to the rolling of the rollers) and motion at an angle to the horizontal, but overall it is translational. Let us mark the forces.
*Blue vectors represent forces acting on the roller ($N_1$ — the force from the plate on the roller, equal and opposite to the force from the roller on the plate; $F_{fr}$ — the friction force acting on the roller, which causes its rotation; and the reaction force $R$ at point $P$).
Blue vectors represent forces acting on the roller ($N_1$ — the force from the plate on the roller, equal and opposite to the force from the roller on the plate; $F_{fr}$ — the friction force acting on the roller, which causes its rotation; and the reaction force $R$ at point $P$).
*Similar forces act on the smaller-radius roller.
Similar forces act on the smaller-radius roller.
*Red vectors represent forces acting on the plate ($N$ — the total normal force, $mg$ — the gravitational force, and $F_{fr}$ — the friction force from the rollers on the plate).
Red vectors represent forces acting on the plate ($N$ — the total normal force, $mg$ — the gravitational force, and $F_{fr}$ — the friction force from the rollers on the plate).
We choose the $Ox$ axis along the velocity of the plate. The velocity itself is the instantaneous velocity of the point of contact between the plate and the roller, while point $P$ is the instantaneous center of velocity. The velocity $v$ is perpendicular to $PC$ (the instantaneous radius of rotation).
We choose the $Ox$ axis along the velocity of the plate. The velocity itself is the instantaneous velocity of the point of contact between the plate and the roller, while point $P$ is the instantaneous center of velocity. The velocity $v$ is perpendicular to $PC$ (the instantaneous radius of rotation).
Writing the equation of motion for the plate in projections on the $Ox$ axis:
Writing the equation of motion for the plate in projections on the $Ox$ axis:
$$
$$
ma = mg \sin\frac{\alpha}{2} + N \sin\frac{\alpha}{2} - F_{fr}\cos\frac{\alpha}{2}\tag{1}
ma = mg \sin\frac{\alpha}{2} + N \sin\frac{\alpha}{2} - F_{fr}\cos\frac{\alpha}{2}\tag{1}
$$
$$
This equation contains three unknowns. We need more equations.
This equation contains three unknowns. We need more equations.
Now let’s write the rotational equation of motion for the roller:
Now let’s write the rotational equation of motion for the roller:
$$
$$
I \varepsilon = \Sigma M
I \varepsilon = \Sigma M
$$
$$
That is, the product of the moment of inertia and the angular acceleration equals the sum of the torques acting on the roller.
That is, the product of the moment of inertia and the angular acceleration equals the sum of the torques acting on the roller.
@@ -42,19 +35,18 @@Solution:
The lever arms of the forces acting on the roller (relative to $PC$) are:
The lever arms of the forces acting on the roller (relative to $PC$) are:
*For force $F_{fr}$:
For force $F_{fr}$:
$$
$$
2r \cos^2 \frac{\alpha}{2}
2r \cos^2 \frac{\alpha}{2}
$$
$$
*For force $N$:
For force $N$:
$$
$$
2r \cos\frac{\alpha}{2}\cdot\sin\frac{\alpha}{2}
2r \cos\frac{\alpha}{2}\cdot\sin\frac{\alpha}{2}
$$
$$
For force $R$: zero.
* For force $R$:
zero.
Thus, the rotational equation for the roller is (since the roller mass is negligible, $I=0$):
Thus, the rotational equation for the roller is (since the roller mass is negligible, $I=0$):
$$
$$
0 = - F_{fr}\cdot 2r \cos^2 \frac{\alpha}{2} + N r \sin\alpha\tag{2}
0 = - F_{fr}\cdot 2r \cos^2 \frac{\alpha}{2} + N r \sin\alpha\tag{2}
